Soft Robotic Arm
Inflatable silicone grippers for industrial robot arms
Overview
Soft robotics meets industrial robots: we designed inflatable silicone grippers so that two KUKA arms could grip, lift, and move an object together.
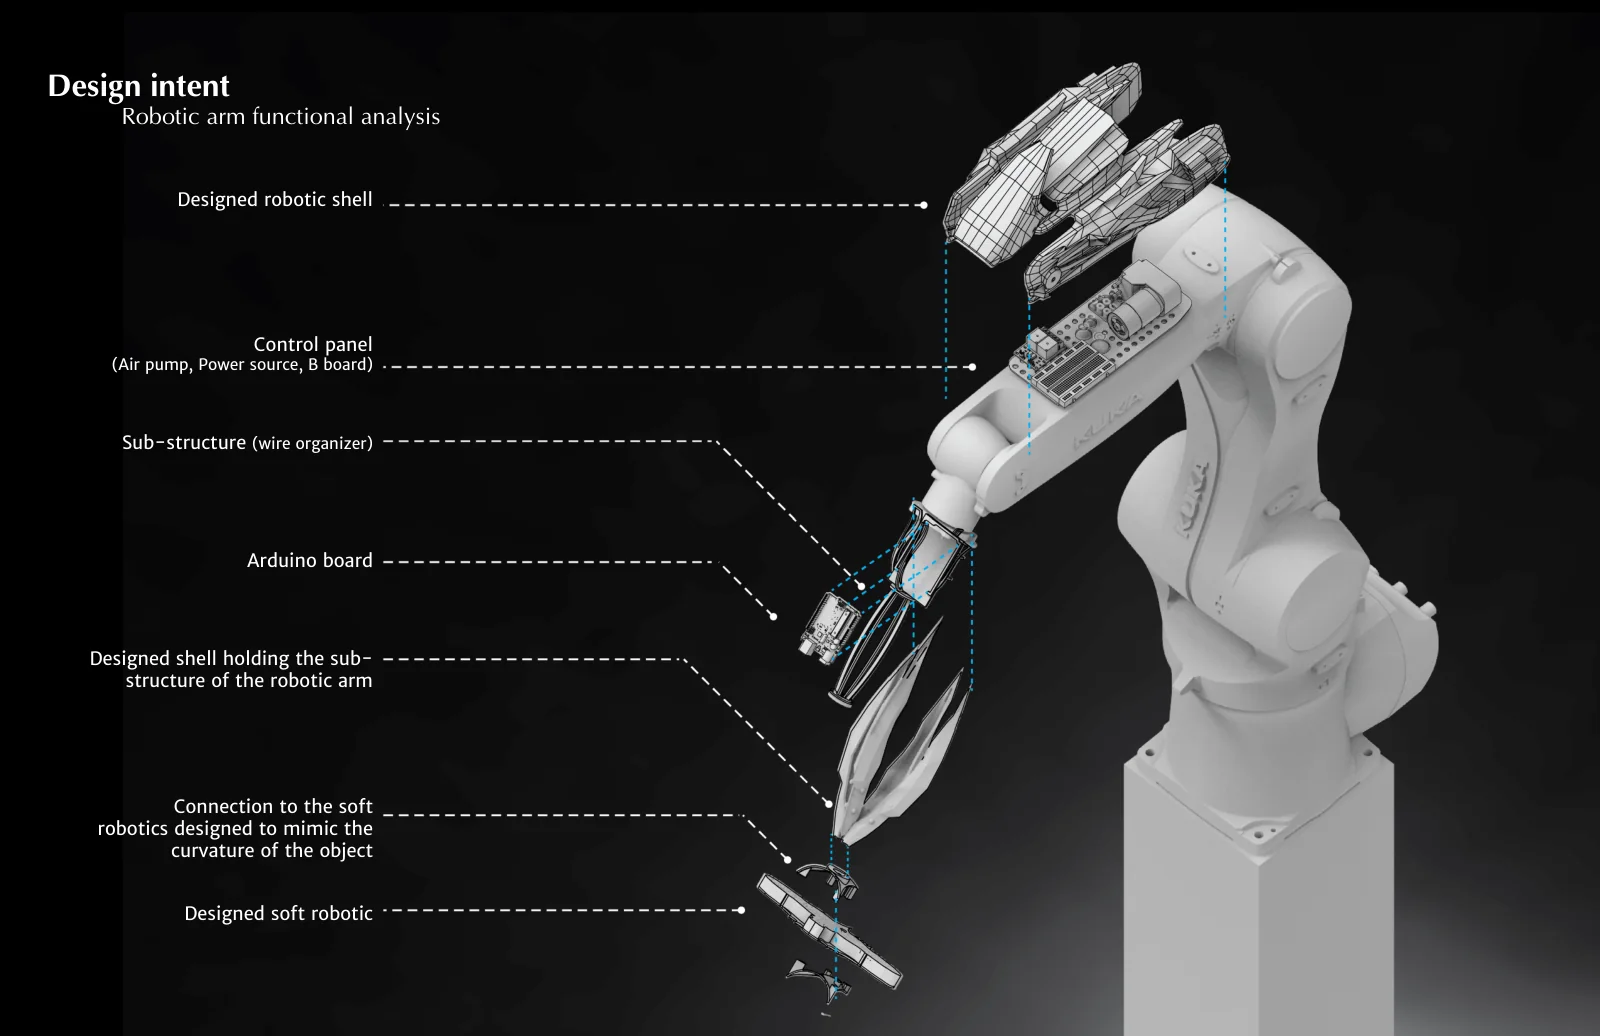
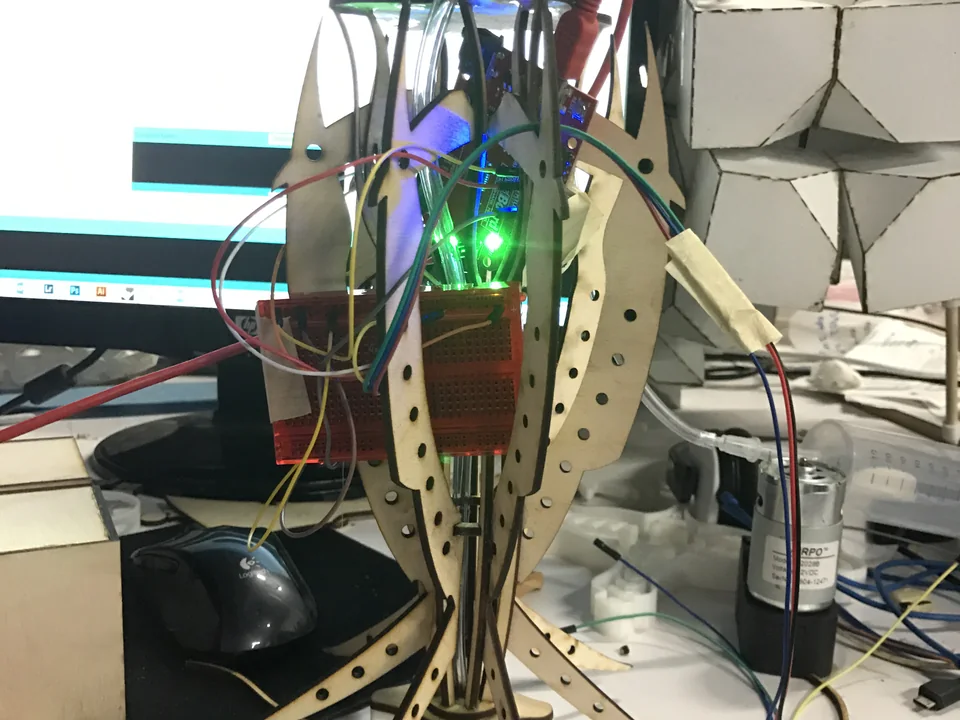
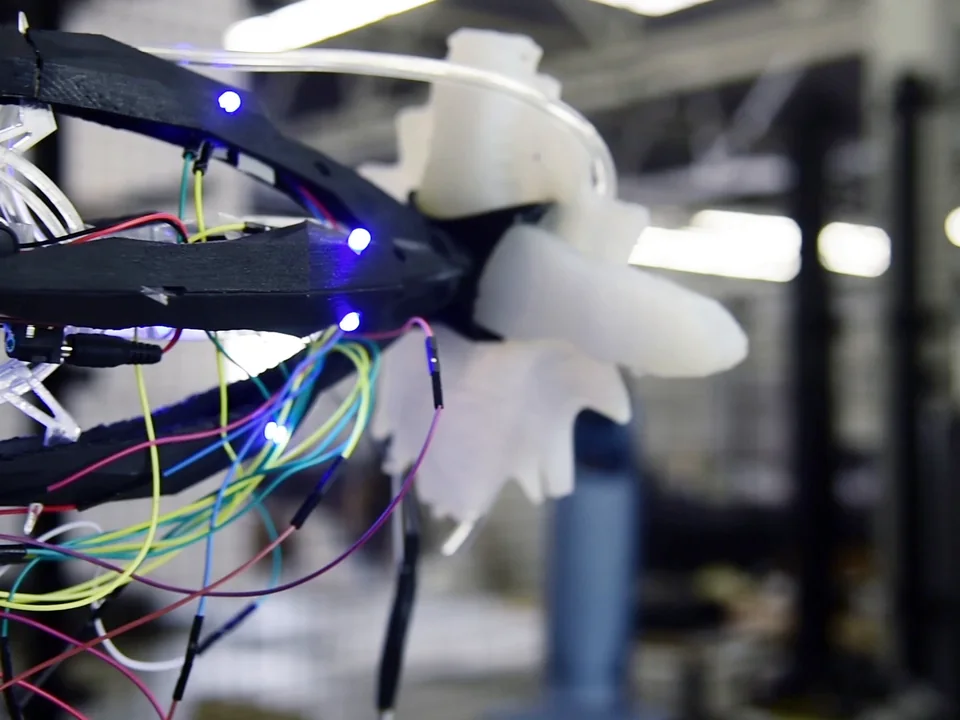
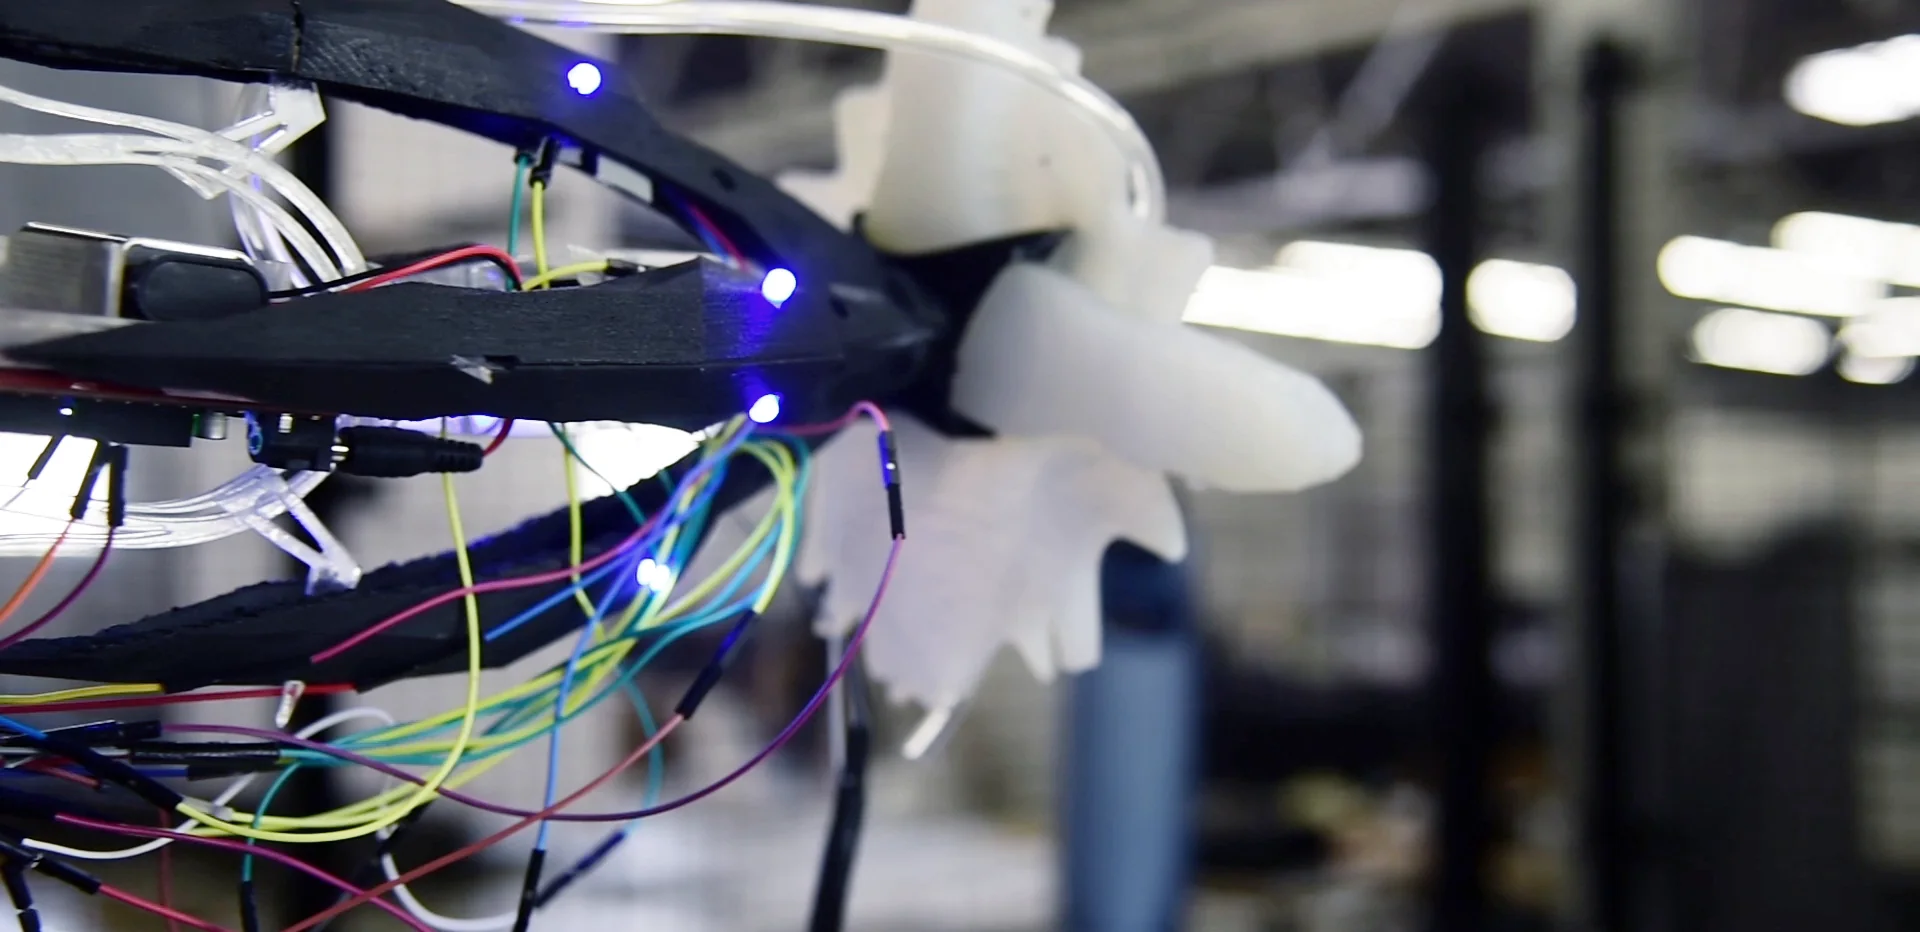
Our assigned object was a metaball, a rounded, multi-lobed shape. We shaped each gripper to its curves, cast it in silicone with air chambers inside, and mounted it on a robot arm with its own air pump, Arduino, and sensor. I worked across the build: form and molds, silicone casting, the Arduino and sensor circuit, robot programming, and the final film.
Final film
Two arms, two soft grippers, one object.
Four phases
The arms move in, the grippers inflate around the object, then the arms lift it and move it together.
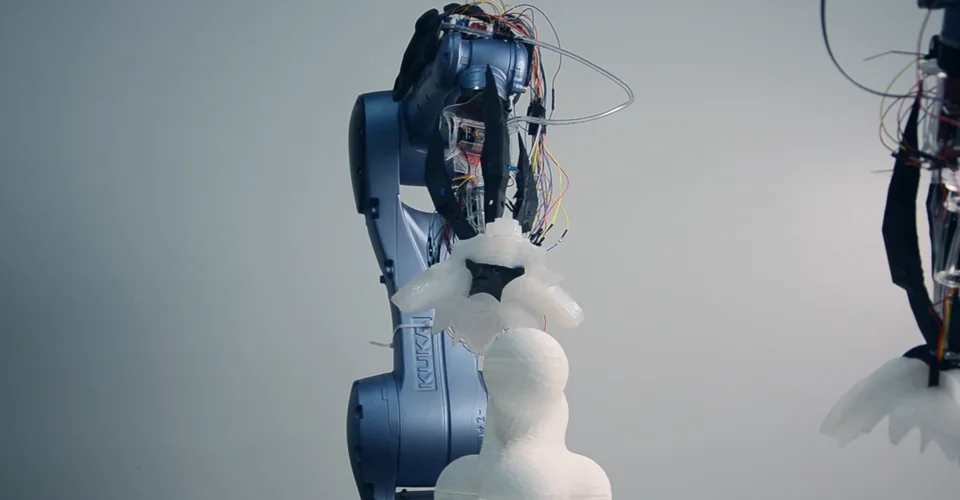
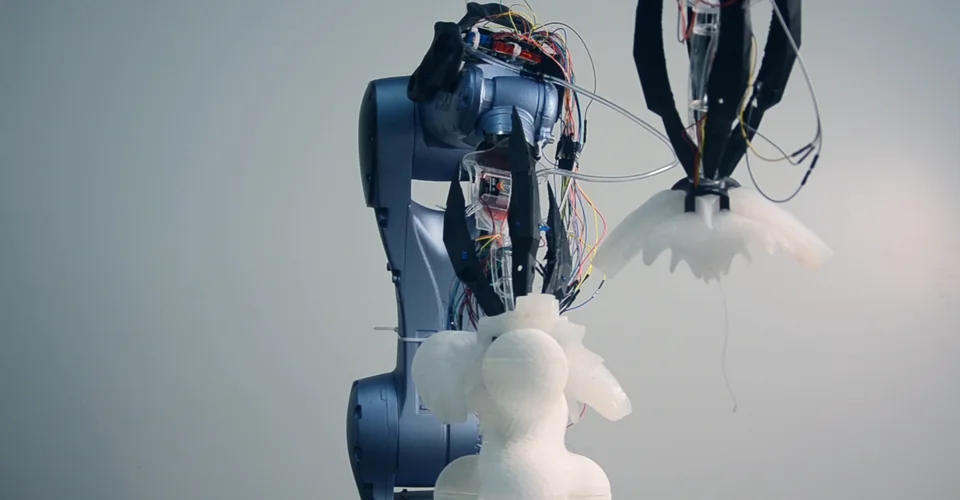
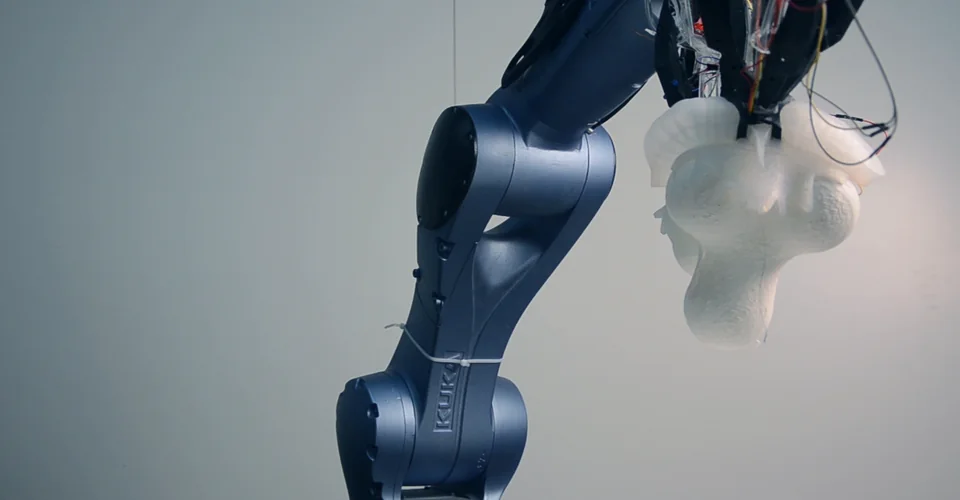
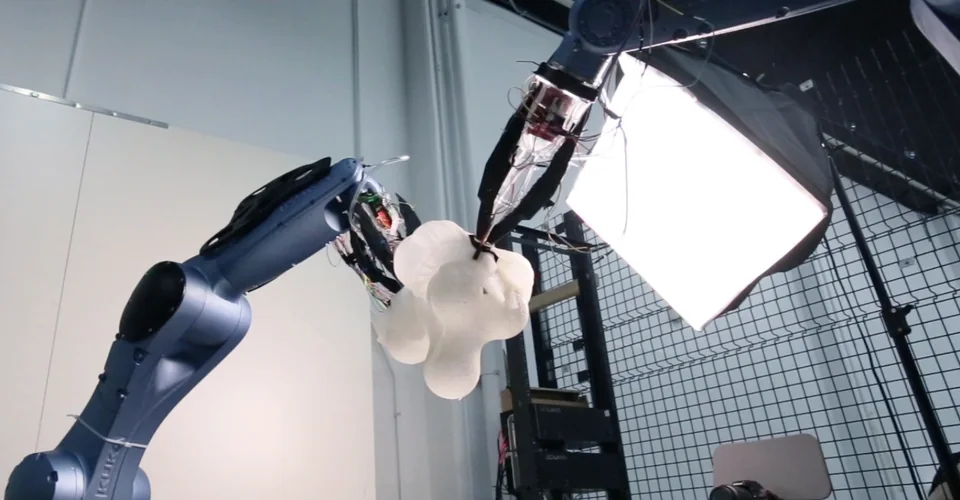
Designed around the object
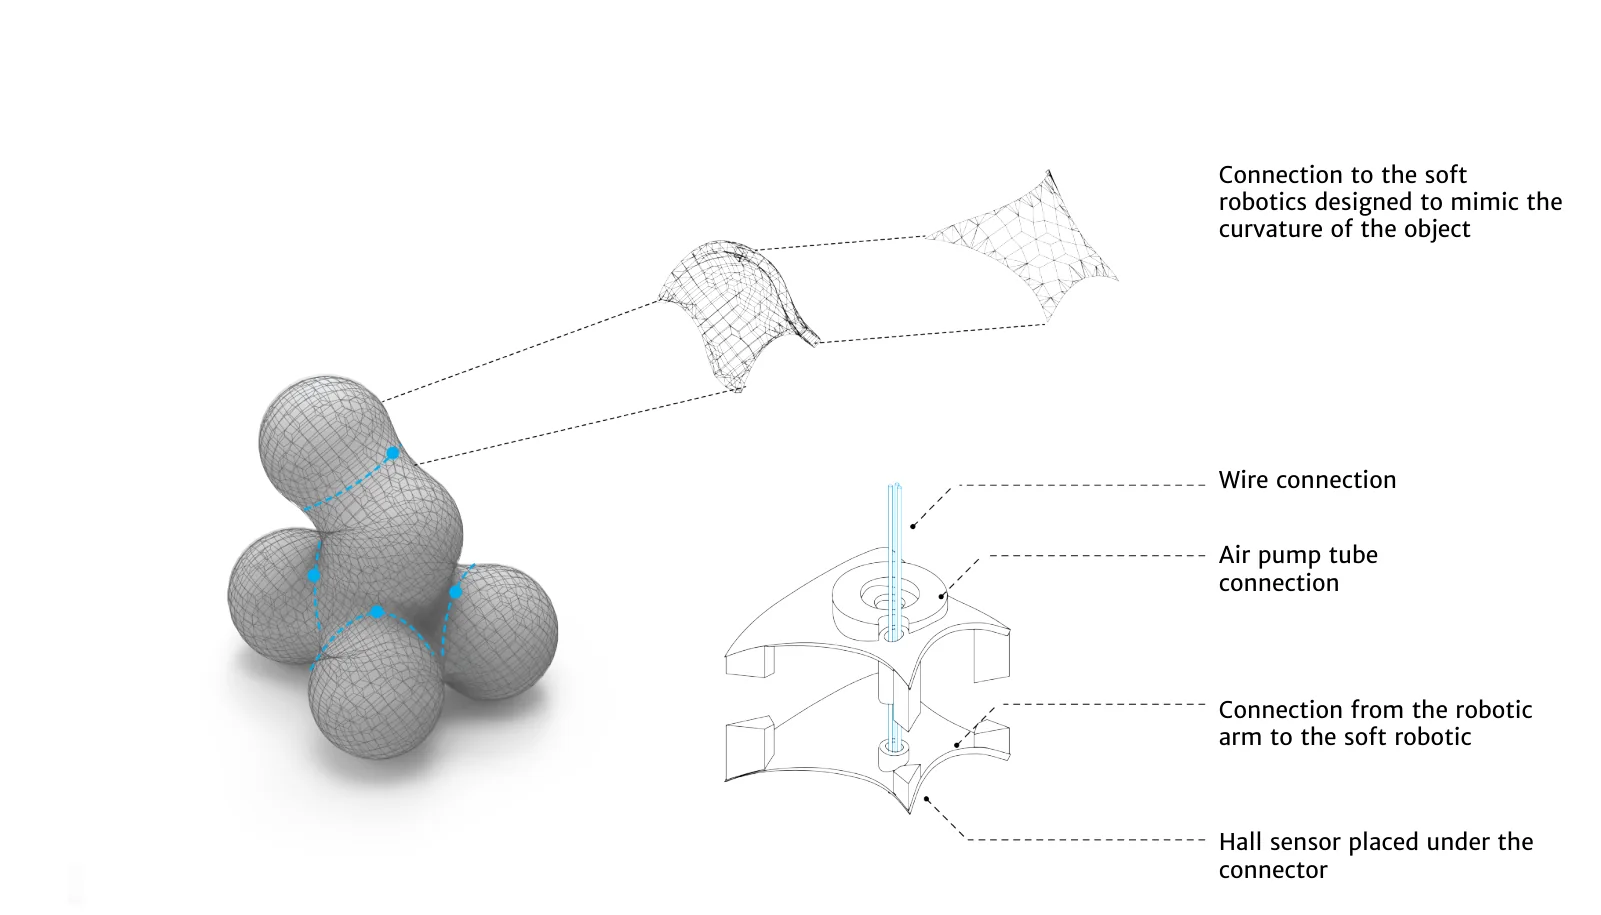
Each gripper is shaped to the metaball's curves. The connector carries the air tube and wiring, with a Hall (magnetic) sensor underneath.
Molds and casting
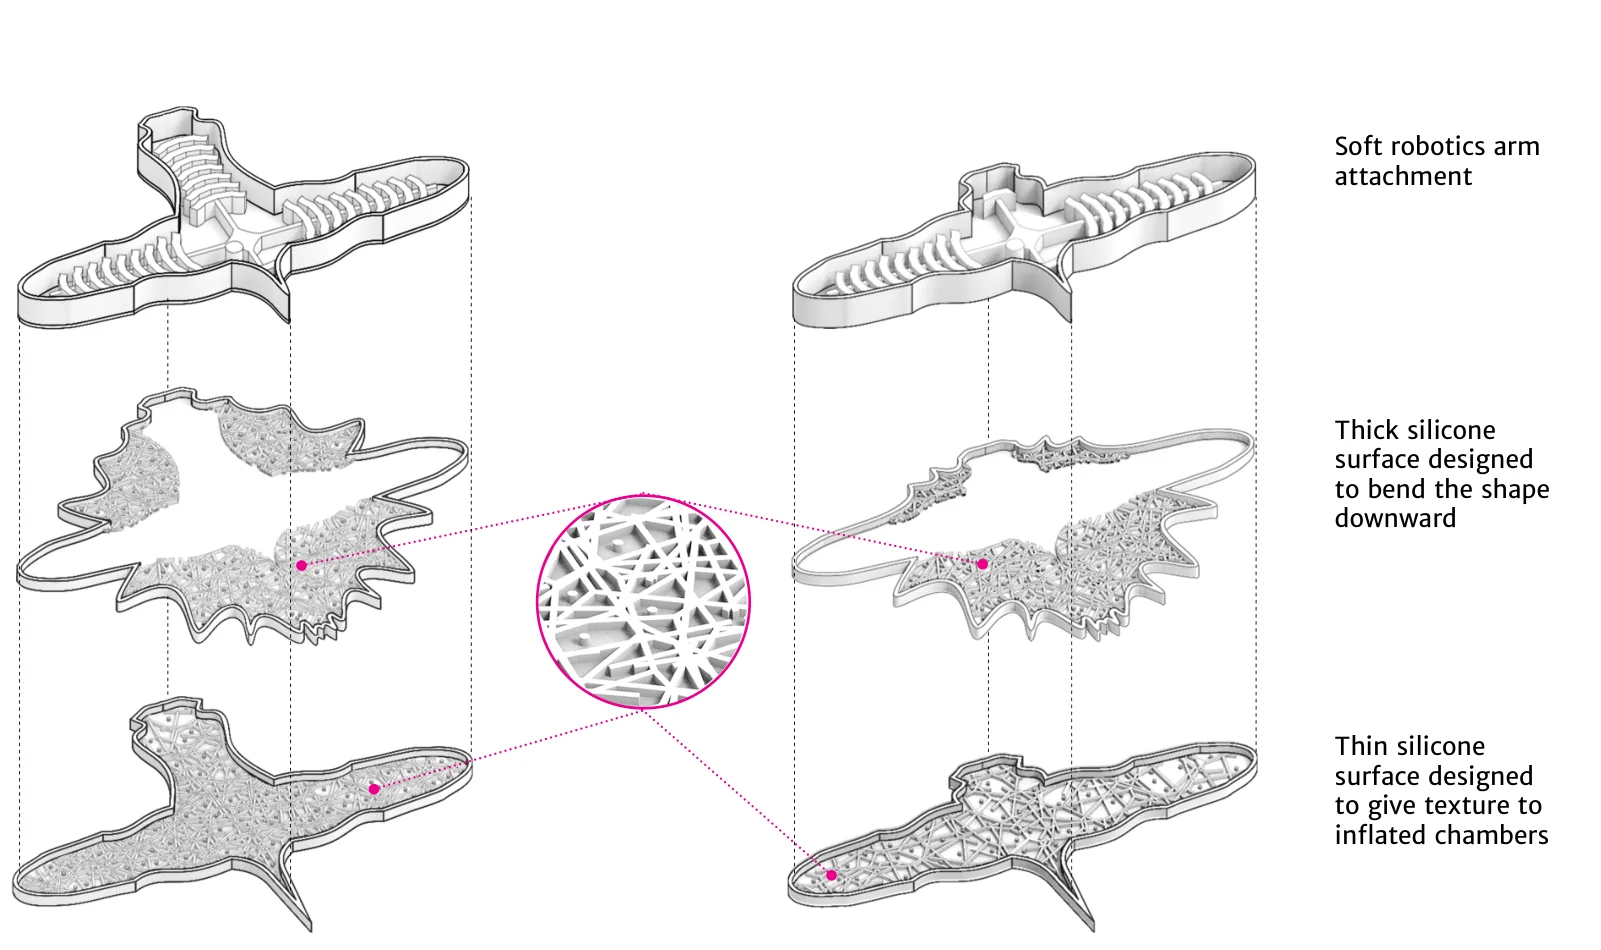
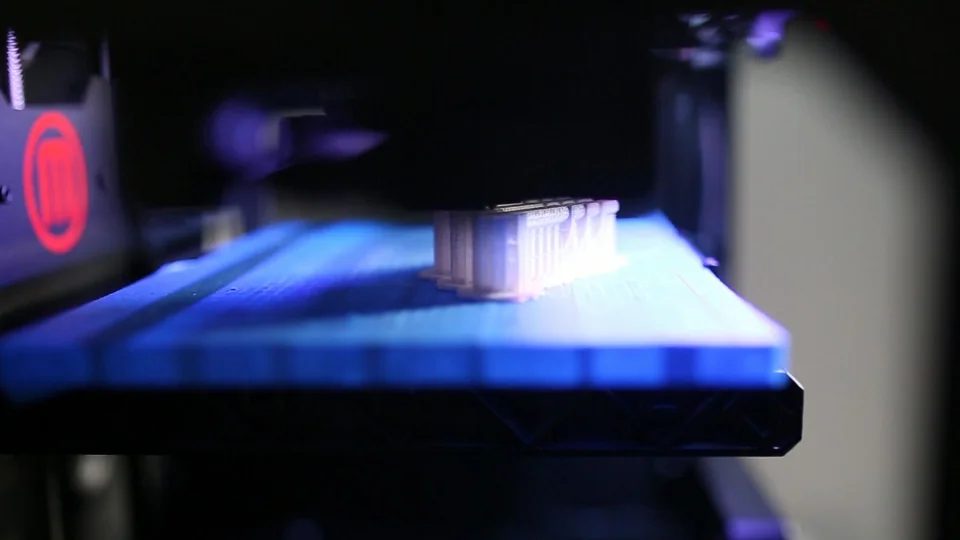
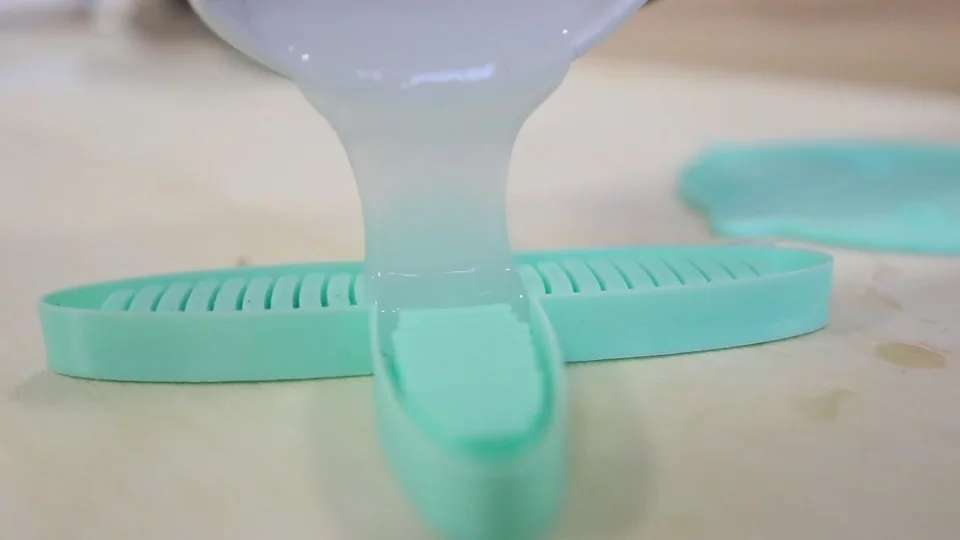
We cast the grippers in silicone using 3D-printed molds. A thicker skin on one side makes each gripper bend downward as its air chambers fill.
Electronics
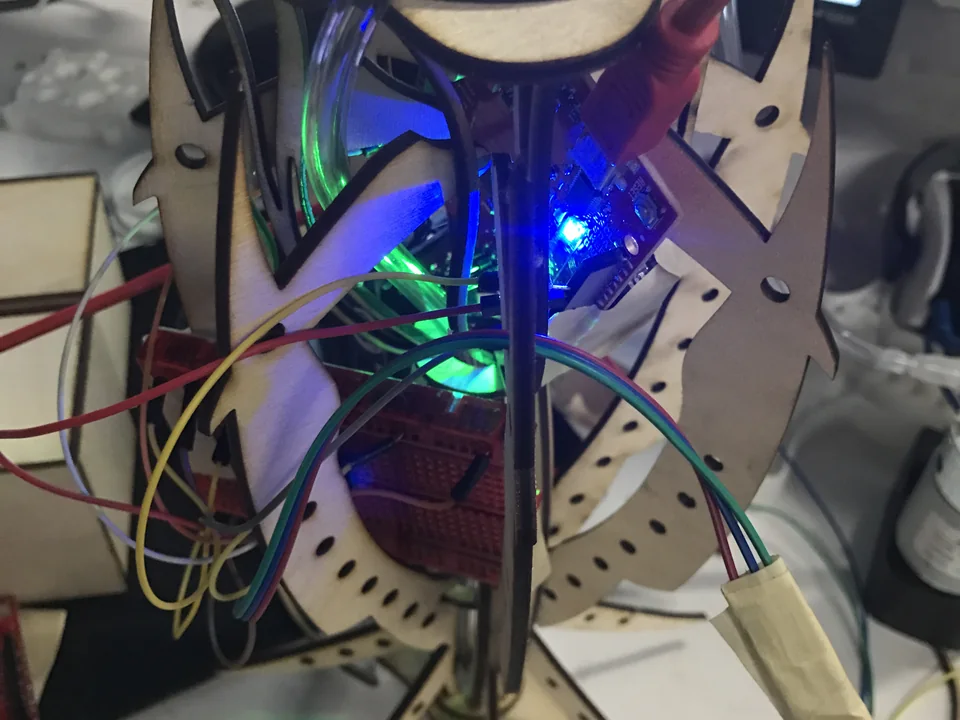
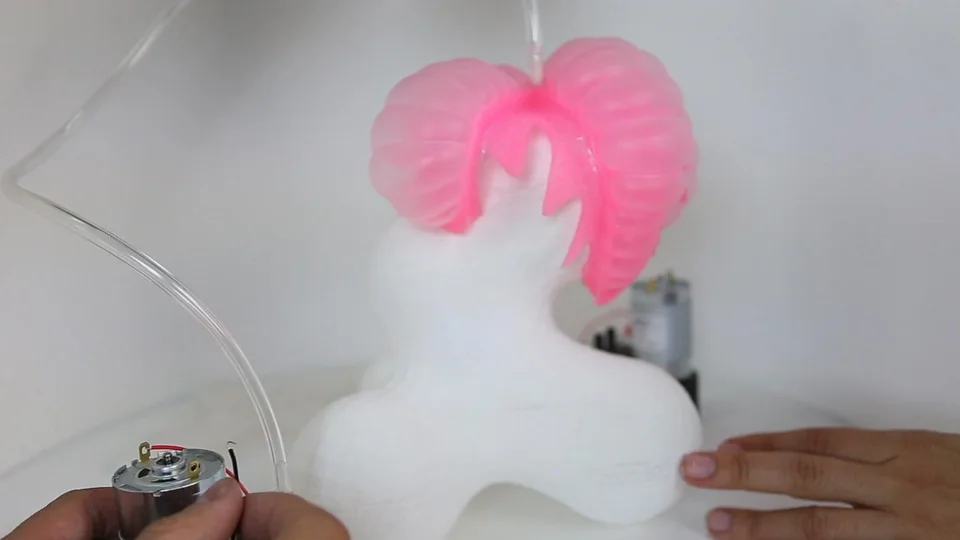
A shell on each arm holds the Arduino, air pump, and power. When the Hall sensor detects a magnet, the Arduino starts the pump to inflate the gripper and lights the LEDs.